 |
pulsatrix
|
|
pulsatrix
|
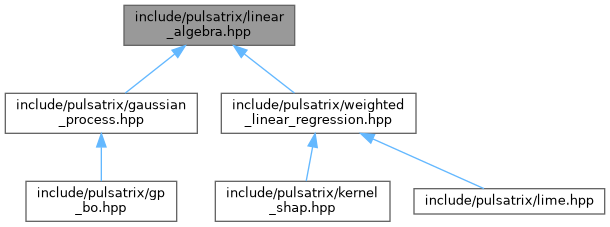
Small, dense linear-system solve – shared by weighted_linear_regression.hpp (Phase 3's LIME/KernelSHAP) and gaussian_process.hpp (this campaign's GP-BO surrogate). More...
#include <cmath>#include <cstdint>#include <stdexcept>#include <utility>#include <vector>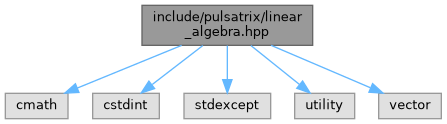
Go to the source code of this file.
Namespaces | |
| namespace | pulsatrix |
Functions | |
| std::vector< float > | pulsatrix::SolveLinearSystem (std::vector< std::vector< float > > a, std::vector< float > b) |
| Solves A*x = b via Gaussian elimination with partial pivoting. | |
Small, dense linear-system solve – shared by weighted_linear_regression.hpp (Phase 3's LIME/KernelSHAP) and gaussian_process.hpp (this campaign's GP-BO surrogate).
detail namespace (2026-09-27, campaign_exai_dl_library_hyperparameter_optimization Phase 2 Mission 0 activation) once a second real consumer (the GP surrogate's posterior mean/variance) needed the identical solver – not duplicated, promoted. Resolves that campaign's own Decision Point (c): GP posterior variance reuses this Gaussian-elimination solver via a second solve per query (K*v = k_star), rather than a new Cholesky-based factor-once/query-many utility – simpler to implement correctly, and sufficient at the small trial counts (tens to low hundreds) this campaign's own Risk Register already scopes GP-BO to. A Cholesky path remains a legitimate future optimization if that scope ever changes, not a correctness requirement now.  1.9.8