 |
pulsatrix
|
|
pulsatrix
|
SAC's reparameterized, tanh-squashed Gaussian policy sampling (action + log-prob). More...
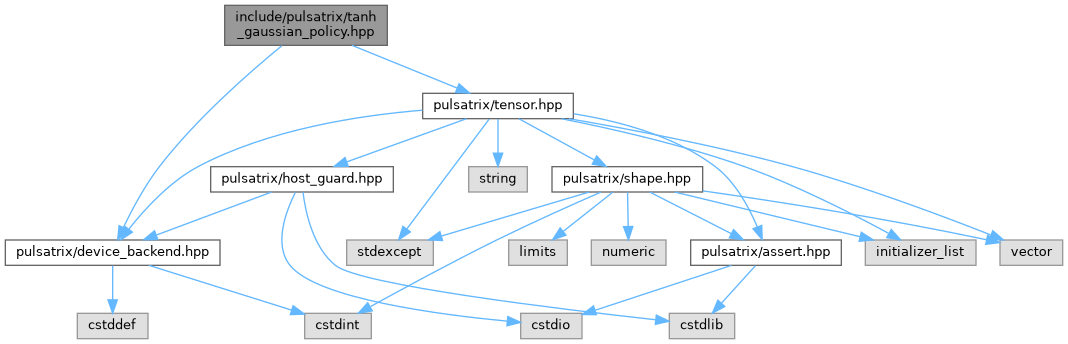
Go to the source code of this file.
Classes | |
| struct | pulsatrix::TanhGaussianSample |
| The (action, log_prob) pair TanhGaussianPolicy::forward() produces. More... | |
| struct | pulsatrix::TanhGaussianGrad |
The (grad_mean, grad_log_std) pair TanhGaussianPolicy::backward() produces – both (N, action_dim), the shape of the forward's own mean/log_std. More... | |
| class | pulsatrix::TanhGaussianPolicy |
SAC's reparameterized, tanh-squashed Gaussian policy sample (Haarnoja et al. 2018, arXiv:1801.01290, Appendix C "Enforcing Action Bounds"): u = mean + exp(log_std) * epsilon, action = tanh(u), with the change-of-variables corrected log-density log_prob = sum_d [ -0.5*epsilon^2 - log_std - 0.5*log(2*pi) - log(1 - action^2 + 1e-6) ]. More... | |
Namespaces | |
| namespace | pulsatrix |
SAC's reparameterized, tanh-squashed Gaussian policy sampling (action + log-prob).
 1.9.8